Robots · interactive
Why do walking robots fall over?
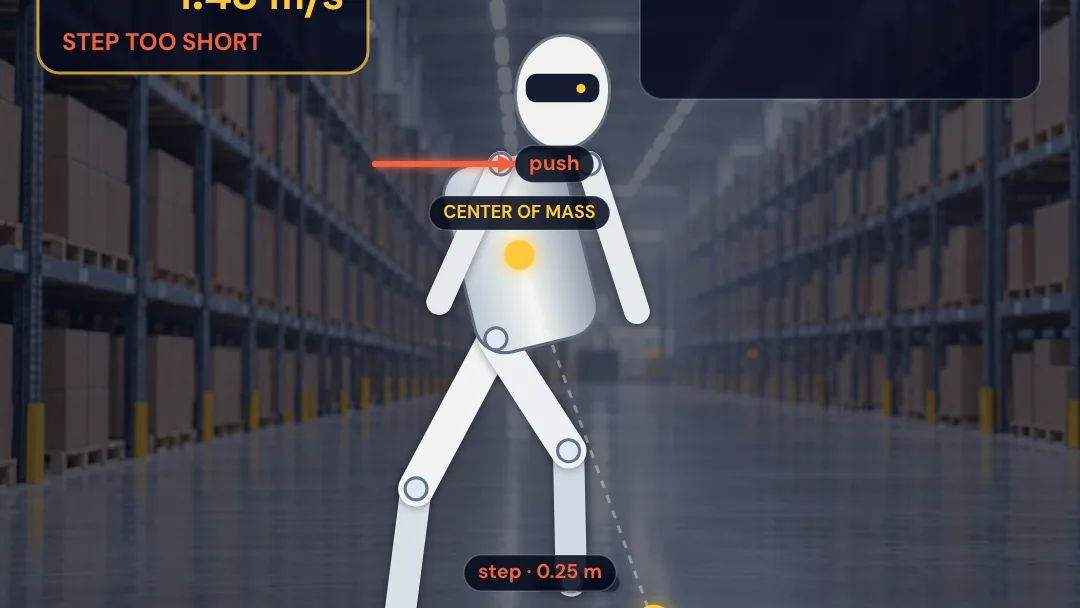
The yellow ring is the capture point: where one ideal step could stop the fall. Change the push, step length and body height.
1 See
Walking deliberately moves the body's weight beyond its support, then catches that fall with the next foot. A push moves the catch point.
2 Change
3 Understand
Model notes and sources
Model. A constant-height linear inverted pendulum with center-of-mass position x, forward speed v and height h. Its natural frequency is ω = √(g/h), and the one-step capture point is ξ = x + v/ω. In this reduced model, landing the next support at ξ can bring the body to rest; a harder push raises v and moves ξ farther ahead.
What the foot means. The tool compares the selected step with the capture point. A step short of ξ is labeled as a topple; a step beyond it is labeled as recoverable. Real humanoids have finite feet, knees, arms, angular momentum, multiple future steps and actuator limits, so their capture region is wider and more complicated than one point.
Update rate. The film's “up to 1,000 times a second” refers to fast balance and joint-control loops, not a claim that every humanoid recomputes a complete footstep plan at 1 kHz. Published humanoid platforms span different rates; PAL Robotics lists a 2 kHz EtherCAT control loop for its Kangaroo biped. Higher-level perception and planning usually run more slowly.
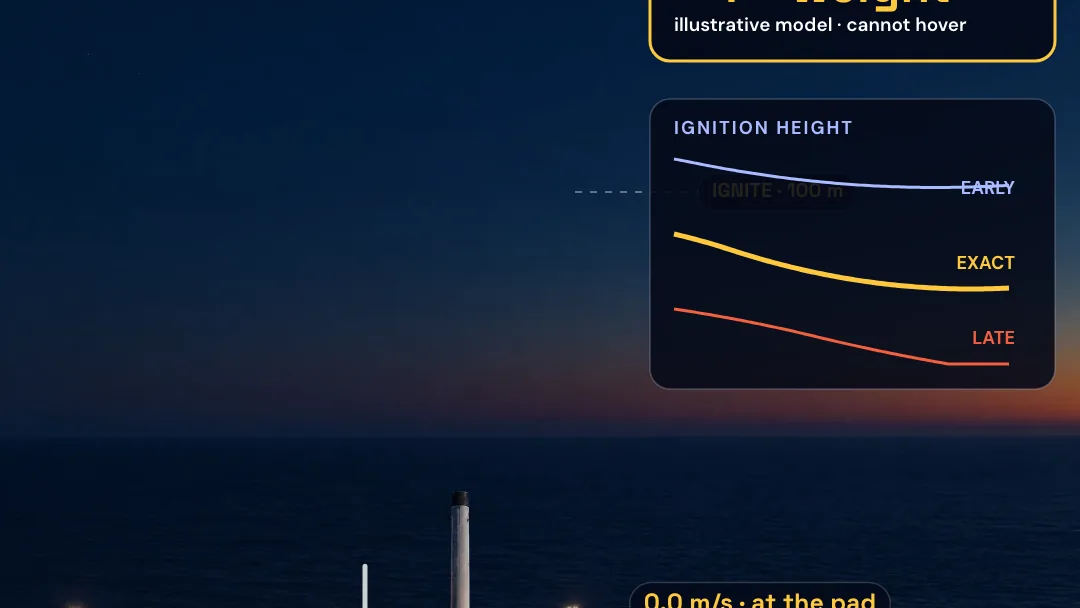
Not modeled. Three-dimensional motion, foot size and pressure distribution, terrain, slipping, compliance, joint torque limits, swing-foot travel time, arm motion and multi-step recovery. The warehouse and hook robot are AI-generated illustrations; the mechanism, target points and numbers are drawn from the model.
Sources: Pratt et al. (2006), Capture Point: A Step toward Humanoid Push Recovery; Kajita et al. (2001), The 3D Linear Inverted Pendulum Mode; PAL Robotics, Kangaroo biped platform (2 kHz control loop).
An ExplainerTools Original.